Image: Caltech / Northeastern University
Amphibious & Multi-Modal
Origin: United States
Research platform
Morphobot / M4
Multi-Modal Mobility Robot
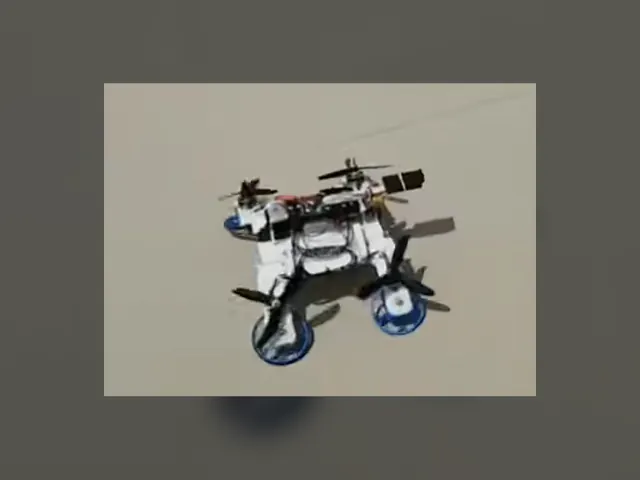
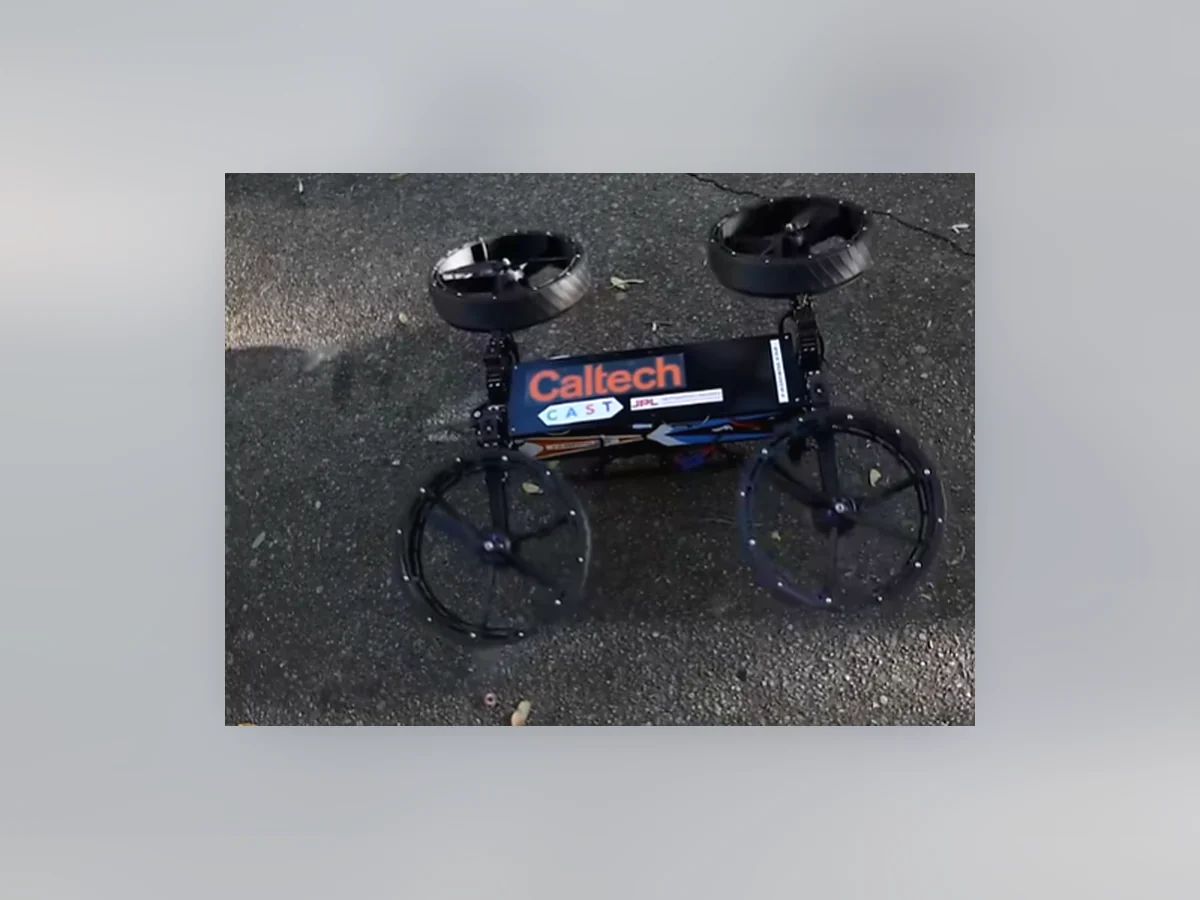
Morphobot is a multi-modal mobility platform developed jointly by Caltech and Northeastern University. A quadruped body with four wheel-and-leg appendages can reconfigure itself between eight locomotion modes, including walking, crawling, rolling, tumbling and flight, because each limb end doubles as a ducted fan that can serve as a wheel, a leg or a wing. The robot is about 70 cm long, 35 cm tall and weighs roughly 6 kg, and it plans its own multi-modal routes without external guidance. Work was published in Nature Communications in June 2024.
Key capabilities
- Eight locomotion modes from a single body
- Wheel-and-leg limbs act as wheels, legs, rotors or wings
- Fully autonomous multi-modal path planning
- Published in Nature Communications
Dimensions
Approx. 70 cm (L) x 35 cm (H)
Weight
Approx. 6 kg
Locomotion
8 modes: walking, crawling, rolling, tumbling, flight and more
Planning
Fully autonomous multi-modal path planning
Prices are not published. Configuration, certification and quantity all affect the figure, so we quote against your requirement.