Image: Fraunhofer IML
Amphibious & Multi-Modal
Origin: Germany
Prototype / R&D stage
evoBOT
Self-Balancing Autonomous Mobile Robot
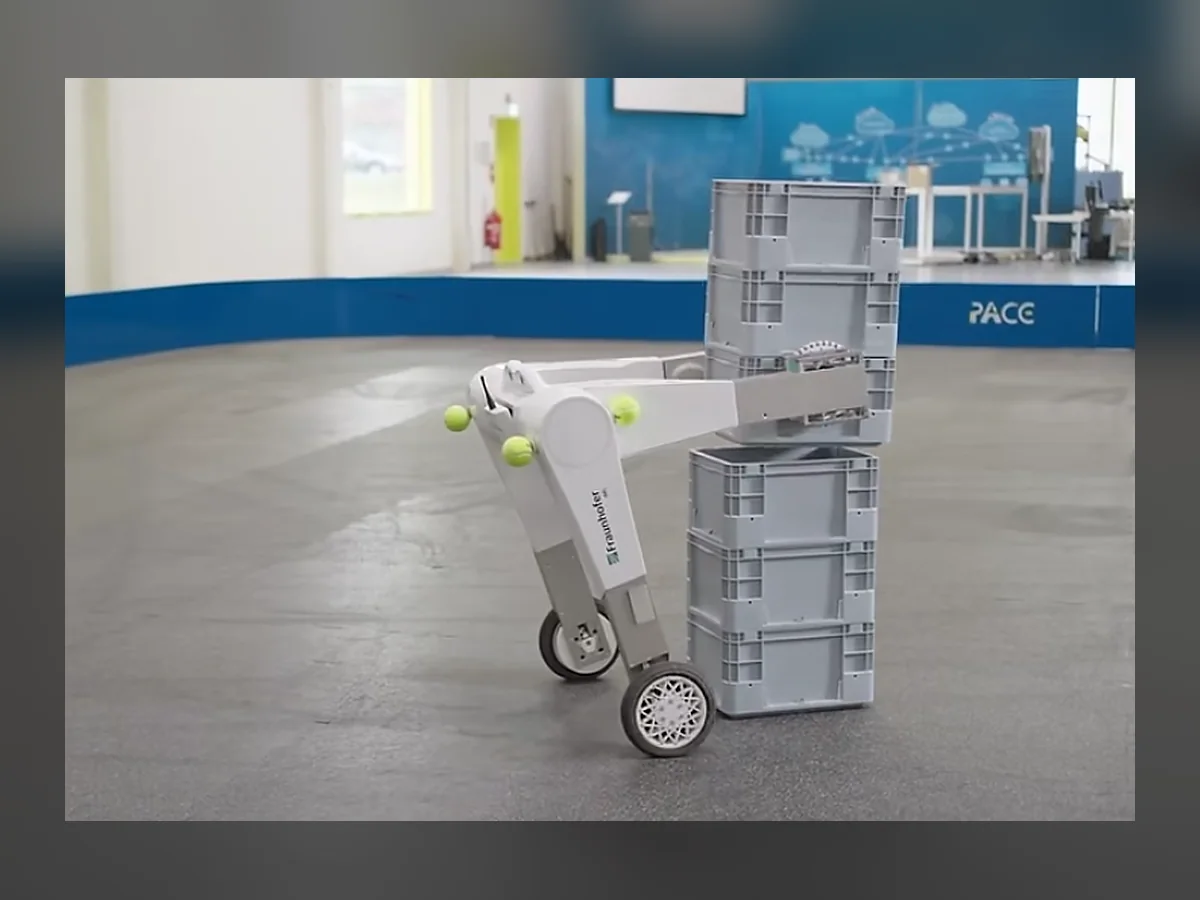
evoBOT is an autonomous transport robot developed by Fraunhofer IML (Institute of Material Flow and Logistics). Its inverted-pendulum balancing design lets a two-wheel base carry a payload while staying upright without a caster or extra support leg, and an integrated arm handles pick-and-place. The platform has been evaluated in live cargo-handling trials at Munich Airport, including movement of hazardous materials and aircraft loading support.
Key capabilities
- Inverted-pendulum self-balancing chassis
- Two-wheel base with integrated robotic arm
- Up to 100 kg payload
- Tested on live airport cargo operations
Locomotion
Two-wheel differential, self-balancing (inverted pendulum)
Payload
Up to 100 kg
Manipulator
Integrated single robotic arm
Typical use
Intralogistics, hazardous-goods transport, aircraft loading
Prices are not published. Configuration, certification and quantity all affect the figure, so we quote against your requirement.